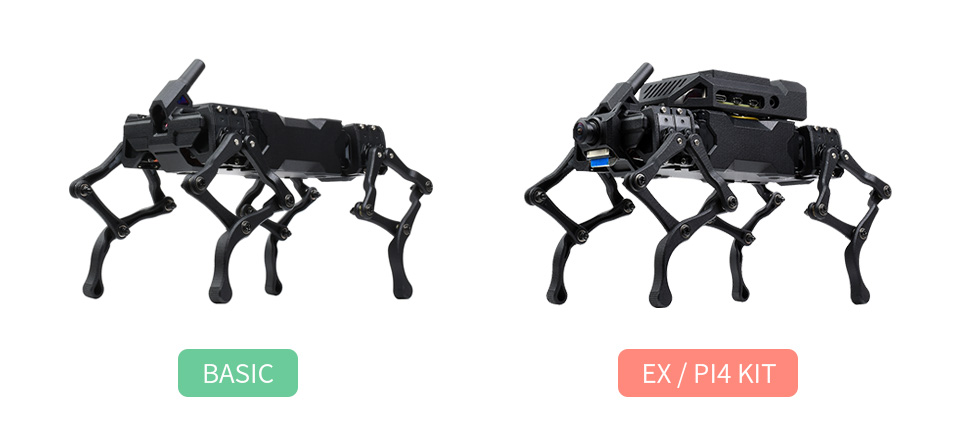
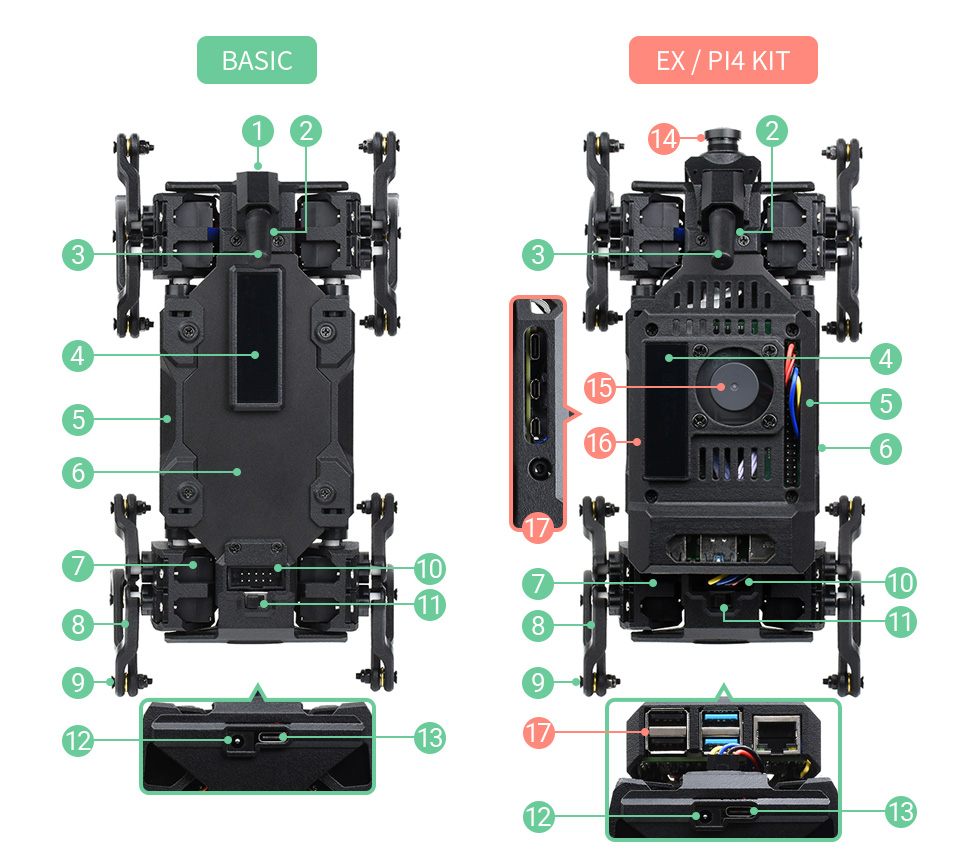
Overview: WAVEGO 12-DOF Bionic Dog-Like Robot is an open-source robotic quadruped featuring dual-controller support for ESP32 and Raspberry Pi 4B, designed for advanced facial recognition, color tracking, and motion detection.
Architecture & Processing Power
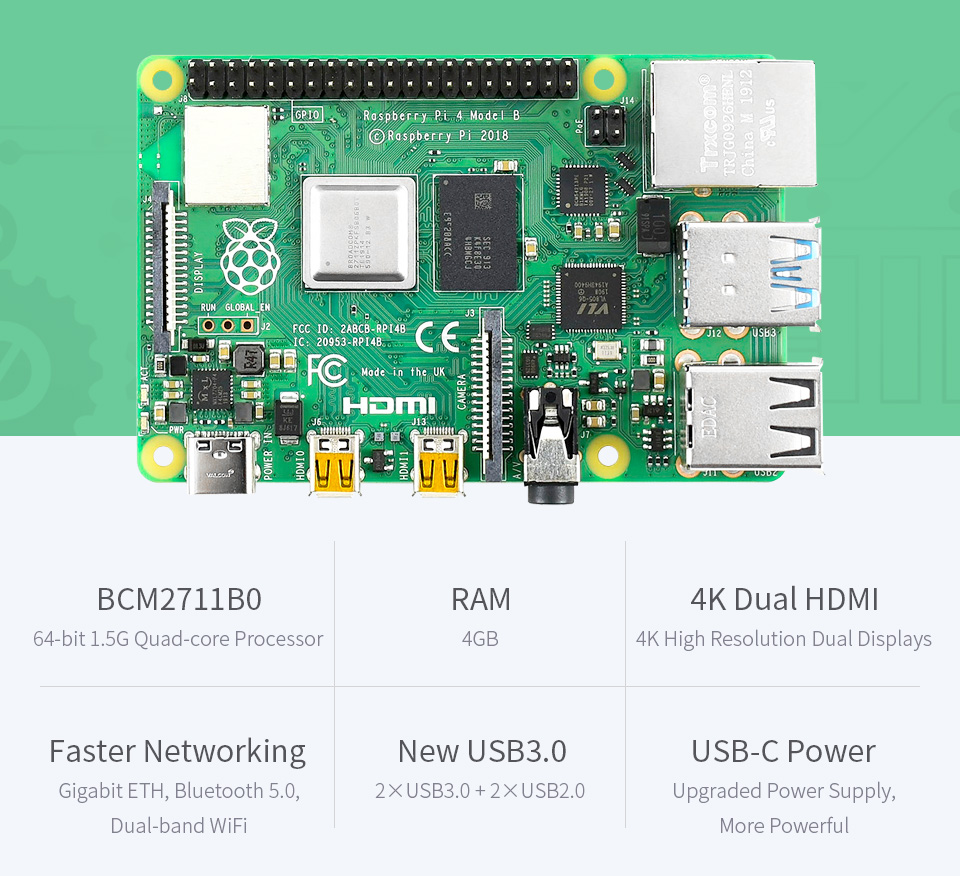
The WAVEGO high-DOF bionic quadruped robot operates on a dual-processing framework. It uses an ESP32 sub-controller dedicated to high-frequency inverse solving of connecting rods and dynamic walk generation, significantly offloading calculation tasks. A Raspberry Pi 4B acts as the host controller responsible for high-level decision-making, visual identification algorithms, and intelligent tracking systems.
Precision Actuation
Fitted with 2.3kg·cm large torque servos, delivering a reliable mechanical structure, optimal balance, and agile, flexible motion capabilities.
Integrated Sensing
Equipped with an onboard front camera, a 9-axis motion tracker, and RGB program status indicators, integrated with an open-source cross-platform web application.
Connectivity & Control
Standard Bluetooth 4.2 support, encompassing both traditional Bluetooth (BR/EDR) and Bluetooth Low Energy (BLE) modes.
Technical Interfaces & Power Management
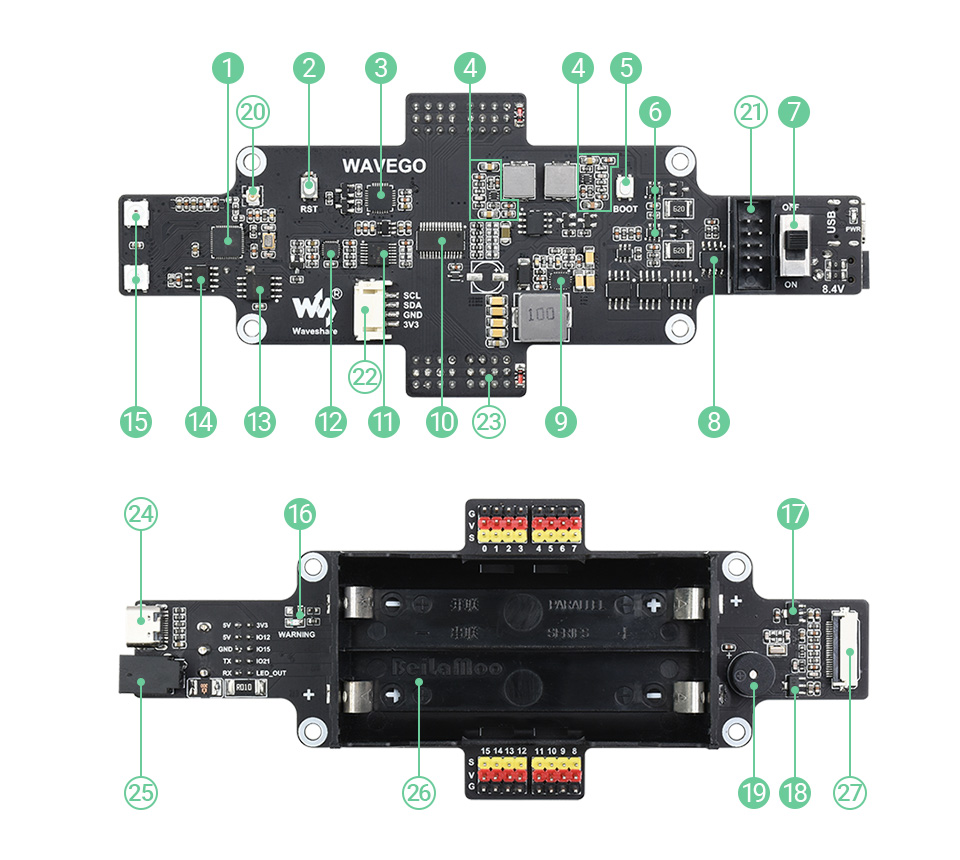
External Ports: 2*5P multi-function extension port (host controller communication, power supply selection, assembly mode selection, etc.).
Interface Expansion: DC battery charger jack, Type-C download port, UART communication, and peripheral expansion headers.
Battery Compatibility: Powered by 18650 Li-ion batteries (not included).
Voltage Range: Supply voltage: 7V - 8.4V; Recharge voltage: 8.4V.
Circuit Safety: Built-in multi-protection system including over-charge protection, over-discharge protection, over-current protection, short-circuit protection, reverse-polarity proof, and equalizing charge for stable and safe operation.
Power Distribution: Independent 5V output designated for host controller power needs.
Documentation: Comprehensive open-source resources and guides are maintained on the official Wiki (resources for different production revisions may vary; please check the Wiki page to confirm actual provided materials).
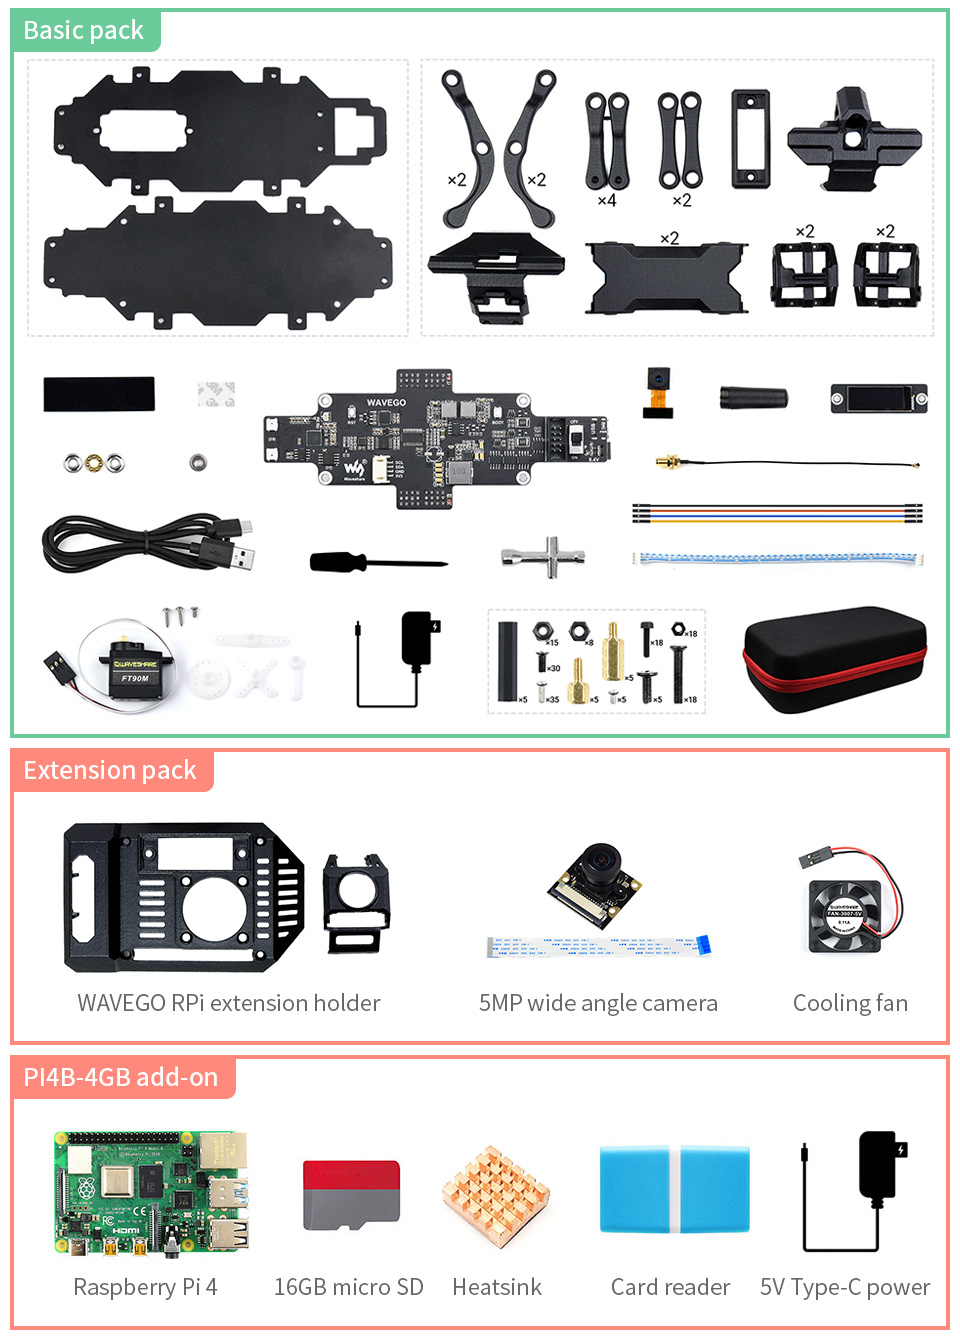
Hardware & Structural Gallery
Frequently Asked Questions (FAQ)
What dual-controller system does the WAVEGO robot use?
The robot utilizes an ESP32 as a sub-controller for inverse kinematic solving and gait generation, while a Raspberry Pi 4B can be connected as the primary host controller for high-level decision tasks like vision processing.
What vision and AI capabilities are built into the platform?
With its integrated camera and 9-axis motion tracker, the platform supports facial recognition, color tracking, and real-time motion detection through multi-platform web applications.
What type of battery is required, and is it included?
The robot requires 18650 Li-ion batteries, which are not included with the standard package. The system operates on a 7V to 8.4V supply voltage with dedicated onboard circuit protections.
What protective circuits are built into the power supply module?
The power board integrates over-charge protection, over-discharge protection, over-current protection, short-circuit protection, reverse-polarity protection, and equalizing charging circuitry.
How do I access technical resources and tutorials?
Extensive development documents and software demos are provided via the product's dedicated open-source Wiki page, which reflects the exact hardware version in use.